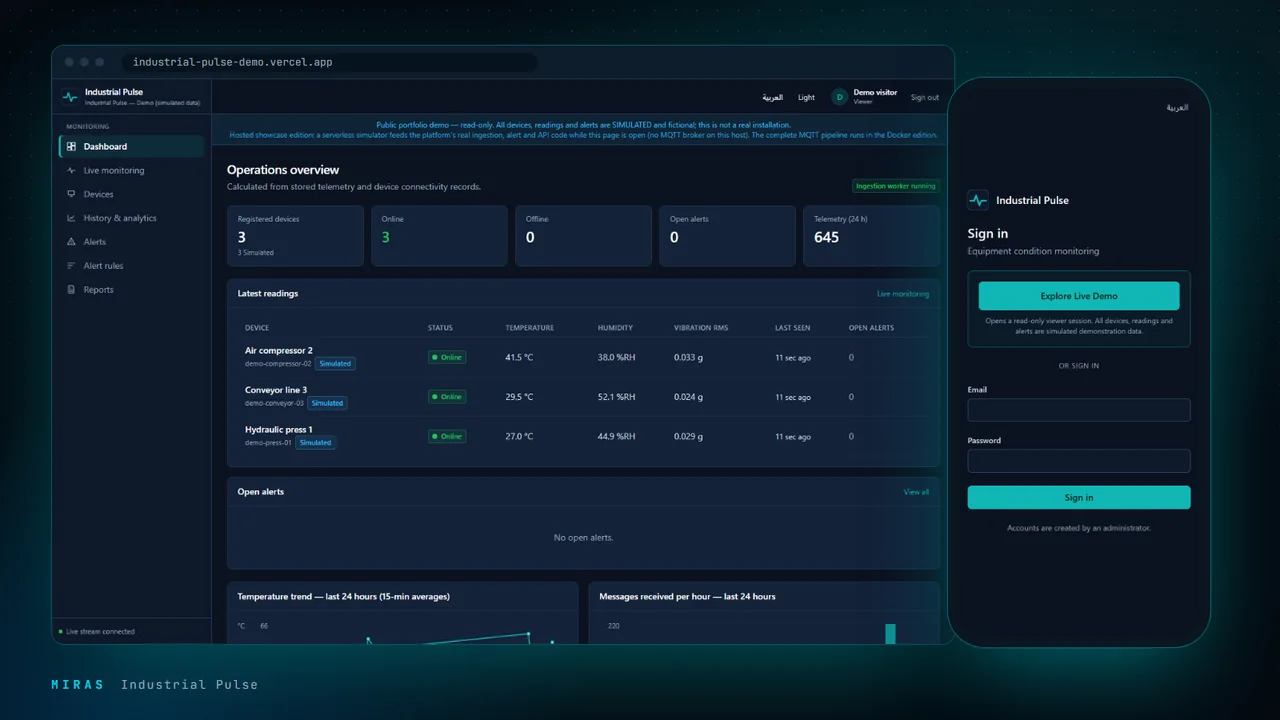
Industrial Pulse
Industrial IoT condition monitoring
From sensor to screen: equipment telemetry over MQTT, stored in PostgreSQL and monitored live on a bilingual dashboard.

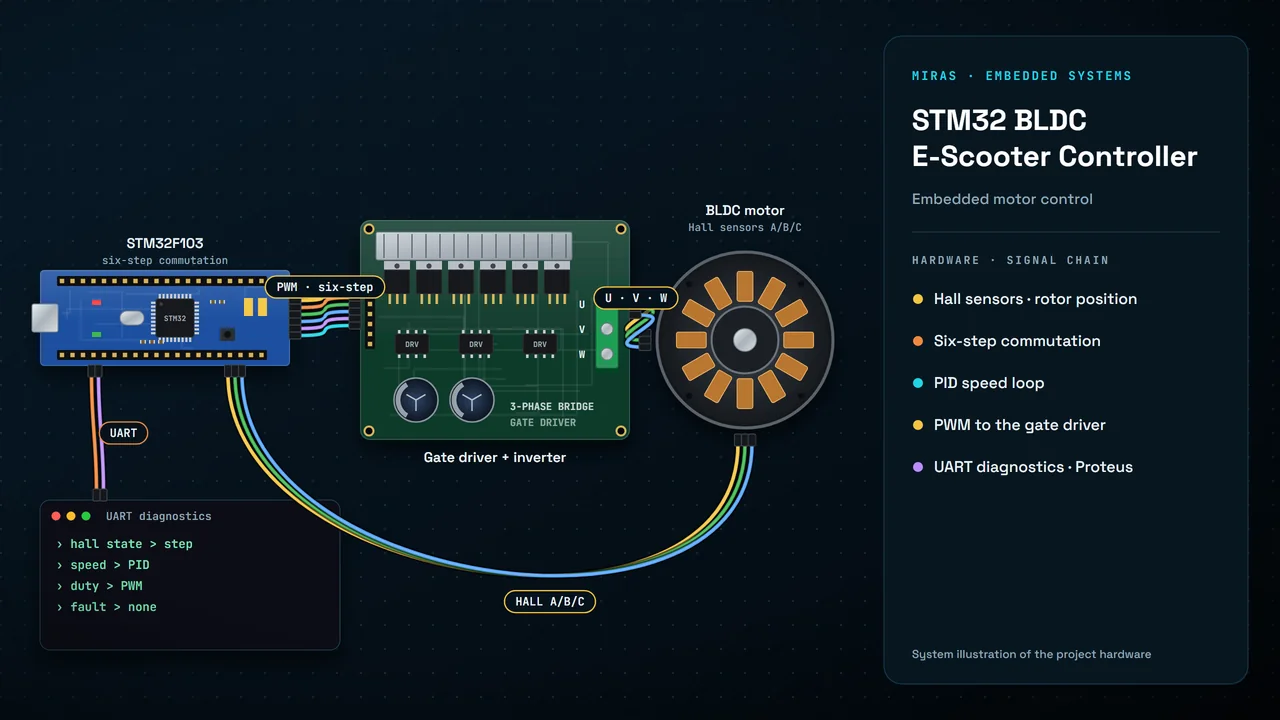
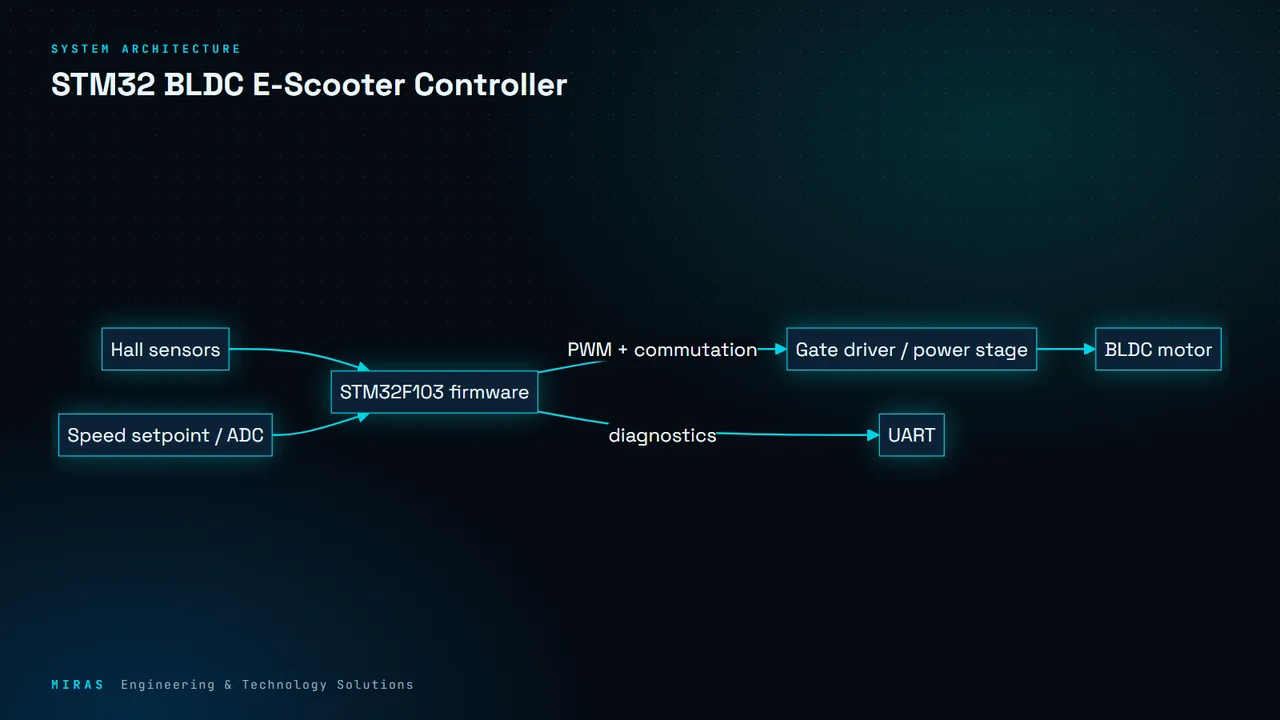
Hall-sensor six-step commutation with closed-loop speed control on STM32F103.
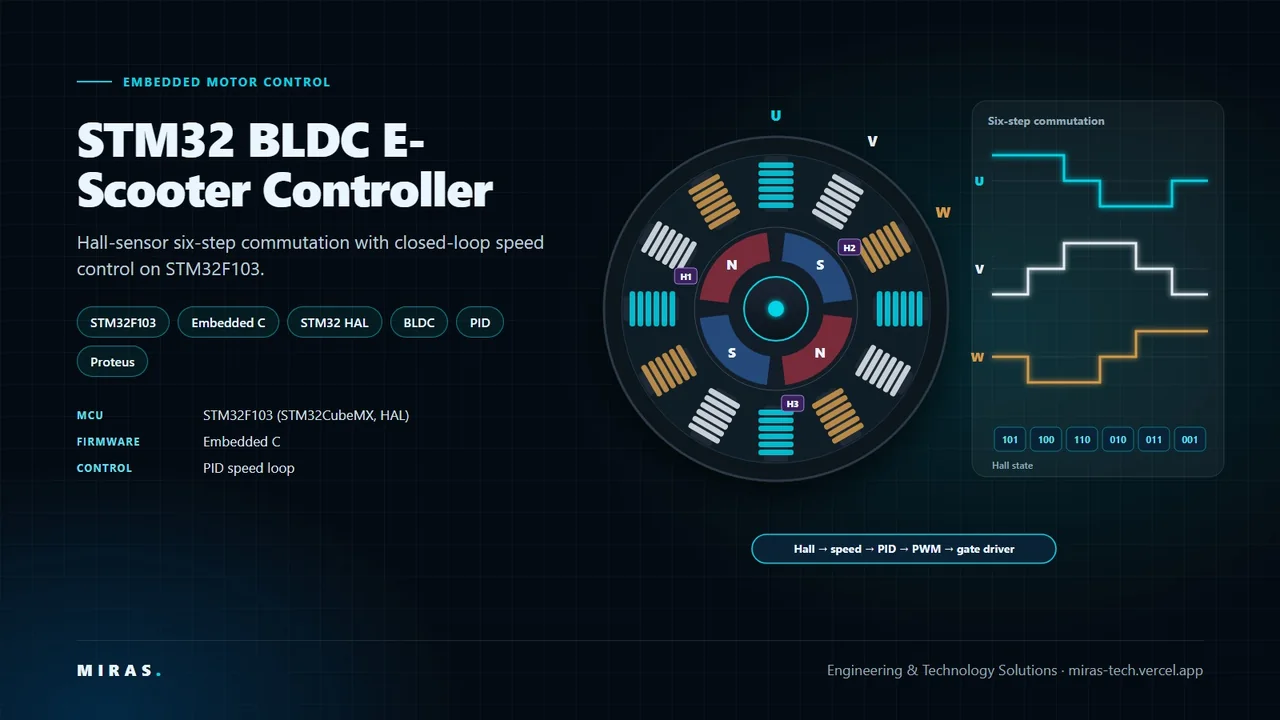
Firmware that drives an e-scooter BLDC motor from an STM32F103. Hall sensors give rotor position for six-step commutation, a speed estimate feeds a PID controller, and the result drives PWM to the gate driver. Proteus and Fritzing assets support simulation and wiring.
The motor must commutate correctly from Hall states at any speed while a speed loop holds the setpoint, all within the interrupt and timer budget of a small MCU.
Industrial IoT condition monitoring
From sensor to screen: equipment telemetry over MQTT, stored in PostgreSQL and monitored live on a bilingual dashboard.
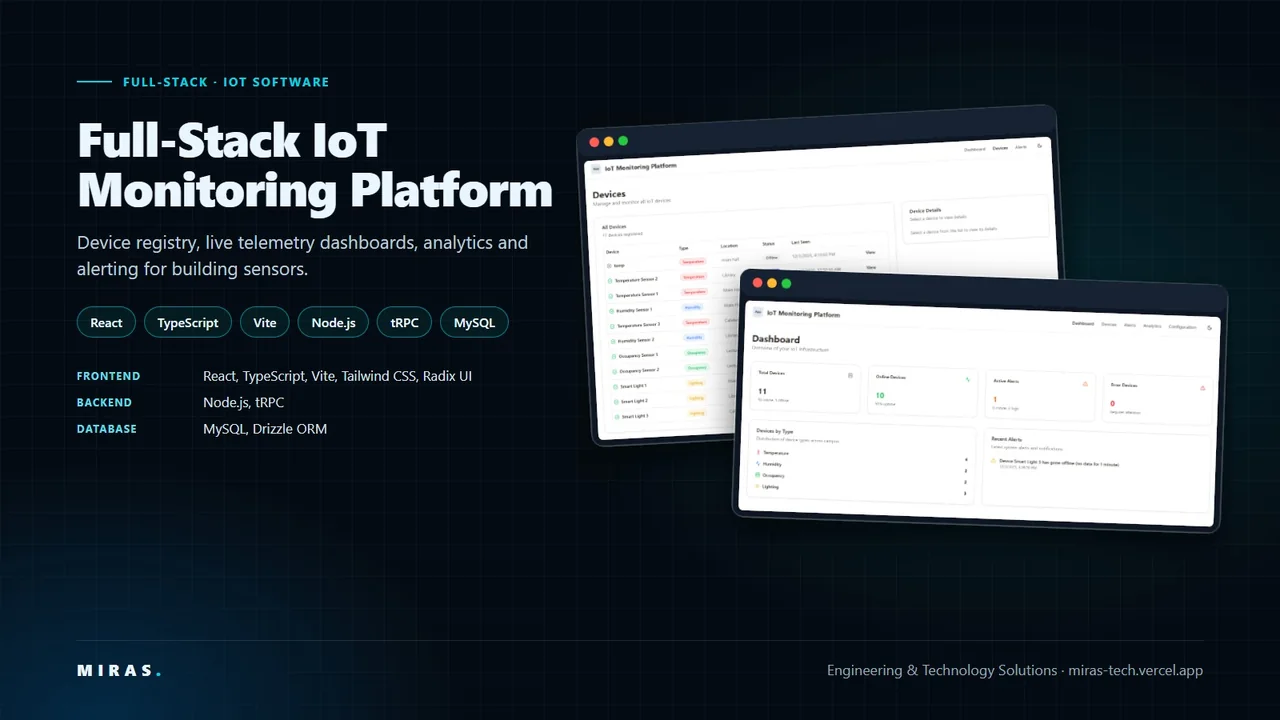
Full-stack IoT software
Device registry, live readings, analytics and alerts for building sensors, in one web platform.
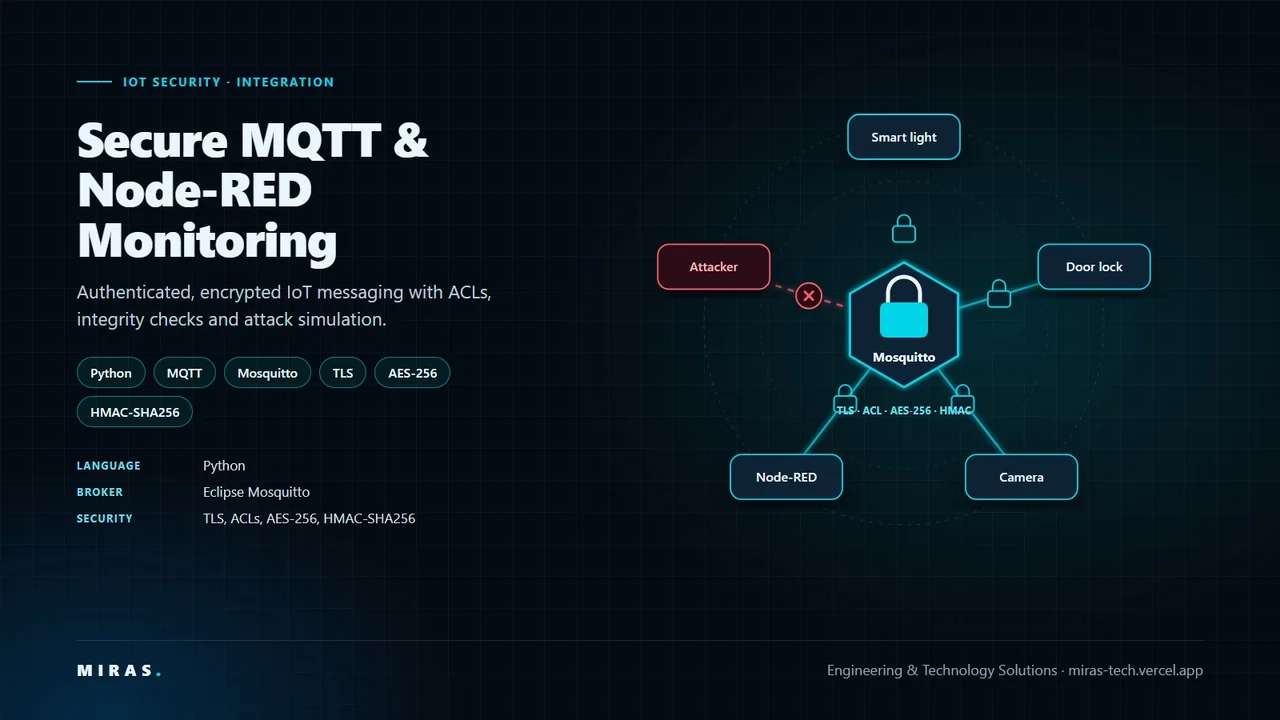
IoT security and integration
Authenticated, encrypted IoT messaging with per-topic access control, message integrity checks and attack simulation.
Tell us where you are starting. We reply with the simplest sensible scope.
Start a project